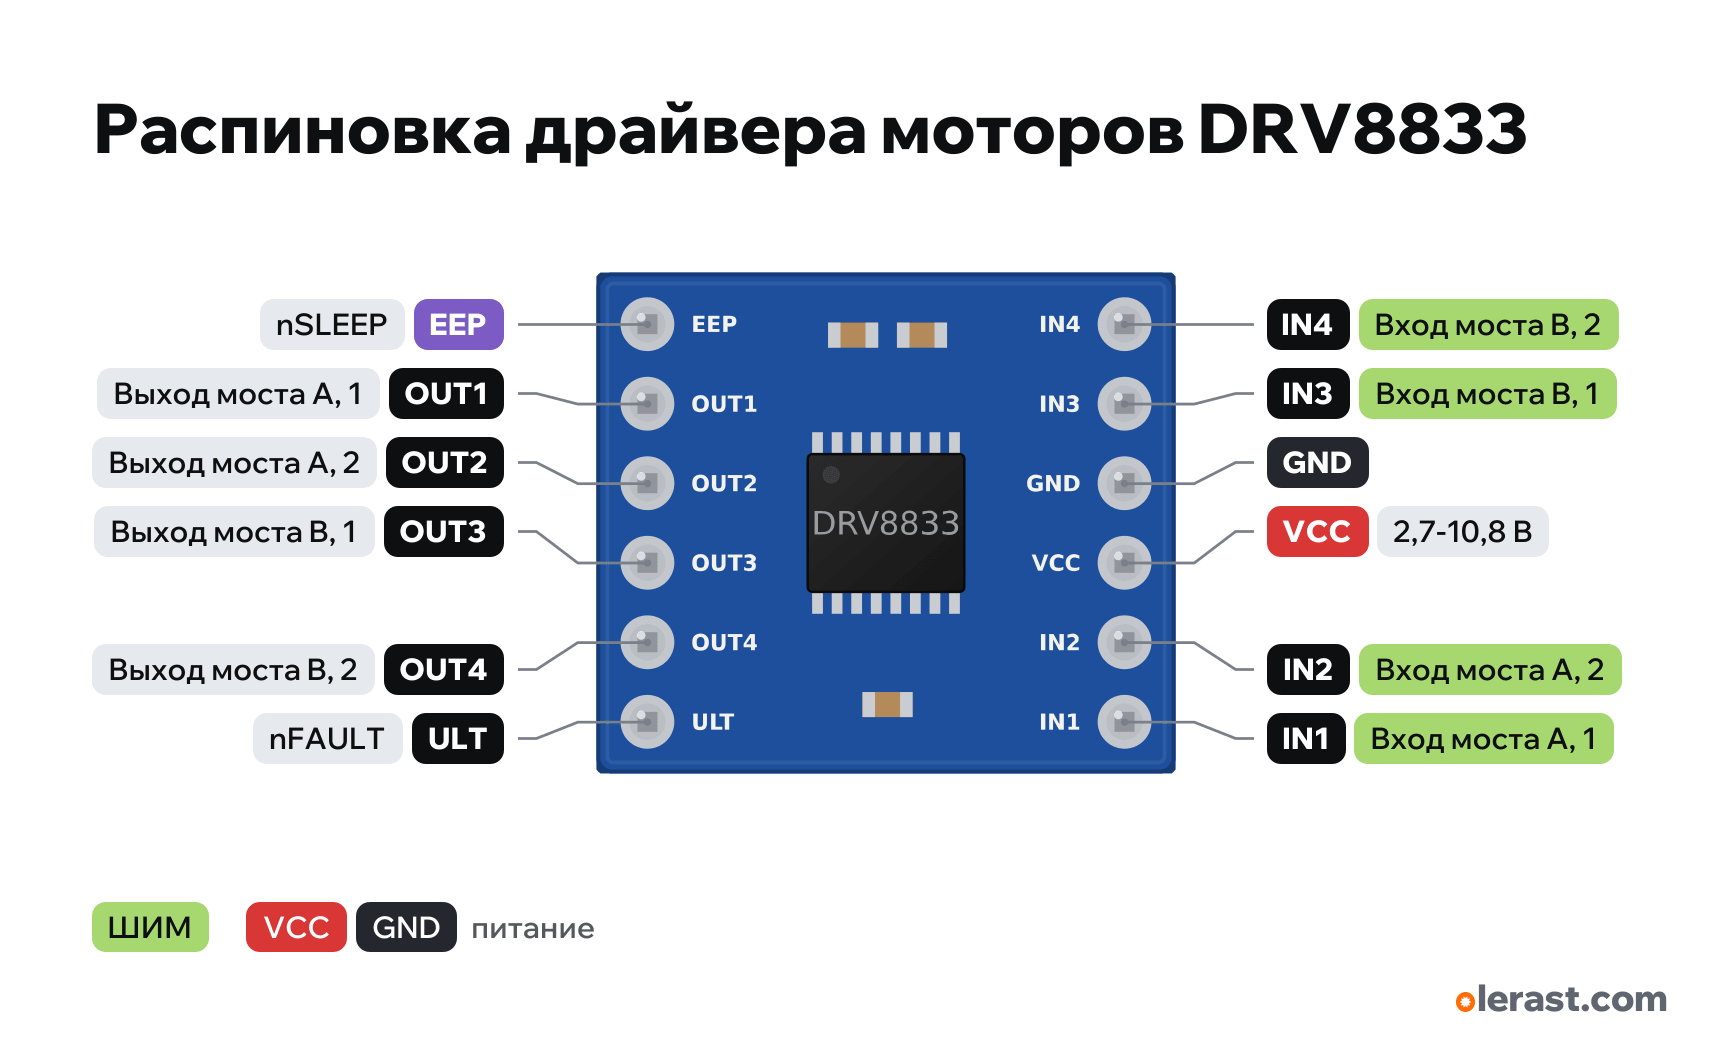
DRV8833 pinout
DRV8833, dual motor driver (HW-627 module, 12 pins), TI DRV8833, 5 V logic, 18.5×16 mm, 12 pins
partly verified17.10.2026
Top view (chip side), rows on the left and right.
Download PNG- Chip
- TI DRV8833
- Logic
- 5 V
- Power
- VCC 2.7-10.8 V
Important
- Bridge A: IN1 and IN2 drive OUT1 and OUT2 (motor A), bridge B: IN3 and IN4 drive OUT3 and OUT4.
- IN1=1, IN2=0 is forward, 0 and 1 is reverse, both 0 is coast, both 1 is brake. Speed: PWM on one of the inputs.
- VCC (VM) 2.7–10.8 V: powers both the motors and the chip. GND is common with the board.
- Without a heatsink keep to 0.5–1 A per bridge: on overheating the chip shuts down and pulls ULT low.
Revisions and clones
- Pololu and Adafruit DRV8833: different layouts and labels (AIN1, AIN2, BIN1, BIN2, SLP, FLT, VM).
- Also sold with an HR8833 chip instead of the DRV8833: same pins.
All pins
| Label | Number | Functions | Limits | Check |
|---|---|---|---|---|
| EEP | nSLEEP: high = run, low = sleep (1.6 µA) | onboard pull-up | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.Jumper J2 on the board ties EEP to VCC: the module is always on. To sleep from a GPIO, desolder the jumper.Labelled on other revisions as: SLEEP, nSLEEP | |
| OUT1 | Bridge A output 1 (AOUT1): to motor A | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.Up to 1.5 A continuous and 2 A peak per bridge, overcurrent and thermal protection. | ||
| OUT2 | Bridge A output 2 (AOUT2): to motor A | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.Up to 1.5 A continuous and 2 A peak per bridge, overcurrent and thermal protection. | ||
| OUT3 | Bridge B output 1 (BOUT1): to motor B | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.Up to 1.5 A continuous and 2 A peak per bridge, overcurrent and thermal protection. | ||
| OUT4 | Bridge B output 2 (BOUT2): to motor B | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.Up to 1.5 A continuous and 2 A peak per bridge, overcurrent and thermal protection. | ||
| ULT | nFAULT: low on overcurrent, overtemperature or undervoltage (open drain) | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.No pull-up on the board: read with INPUT_PULLUP.Labelled on other revisions as: FAULT, nFAULT | ||
| IN4 | Bridge B input 2 (BIN2) | 5 V tolerantonboard pull-down | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.3.3 V and 5 V logic (up to 5.75 V). Internal pull-down. | |
| IN3 | Bridge B input 1 (BIN1) | 5 V tolerantonboard pull-down | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.3.3 V and 5 V logic (up to 5.75 V). Internal pull-down. | |
| GND | Ground | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos. | ||
| VCC | 5 V | power input | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.All motor current flows through this pin: power it from a battery or a supply, not from the board's 3V3.Labelled on other revisions as: VM | |
| IN2 | Bridge A input 2 (AIN2) | 5 V tolerantonboard pull-down | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.3.3 V and 5 V logic (up to 5.75 V). Internal pull-down. | |
| IN1 | Bridge A input 1 (AIN1) | 5 V tolerantonboard pull-down | not from manufacturerNo-brand module: pin numbers match in two KiCad symbols and Components101, layout follows the footprint. Board silkscreen not checked against photos.3.3 V and 5 V logic (up to 5.75 V). Internal pull-down. |
Sources
Not verified against the manufacturer: 12 of 12 pins. The pin card says what confirms each one and where sources disagree.
- TI DRV8833 datasheetdatasheet, checked 17.10.2026VM 2.7–10.8 V, inputs up to 5.75 V with pull-down, 1.5 A continuous, 1.7 mA supply current, 1.6 µA sleep, nFAULT open drain, IN/OUT table
- KiCad: robopoly-pi/Kit_Prisme_NEW HW-627_DRV8833 and DrGlaucous/KiCadParts HW-627third-party source, checked 17.10.202618.5×16; rows of 6, 15.24 mm apart; 1 SLEEP, 2–5 OUT1–OUT4, 6 FAULT, 7 IN1, 8 IN2, 9 VCC, 10 GND, 11 IN3, 12 IN4 (two independent symbols)
- Components101: DRV8833 Dual H-Bridge Motor Driver Modulethird-party source, checked 17.10.2026order EEP, OUT1–OUT4, ULT, IN1, IN2, VCC, GND, IN3, IN4; VCC 2.8–10.8 V
- TinyTronics: DRV8833 motoraansturingthird-party source, checked 17.10.2026jumper J2 keeps the module on, desolder it for sleep; ULT low on a fault; 1.5 A, up to 0.5 A advised without a heatsink
Size: per the KiCad footprint (robopoly HW-627 18.5×16) (approximate).
FAQ
- What supply voltage does the DRV8833 need?
- VCC: 2.7-10.8 V. 5 V logic.