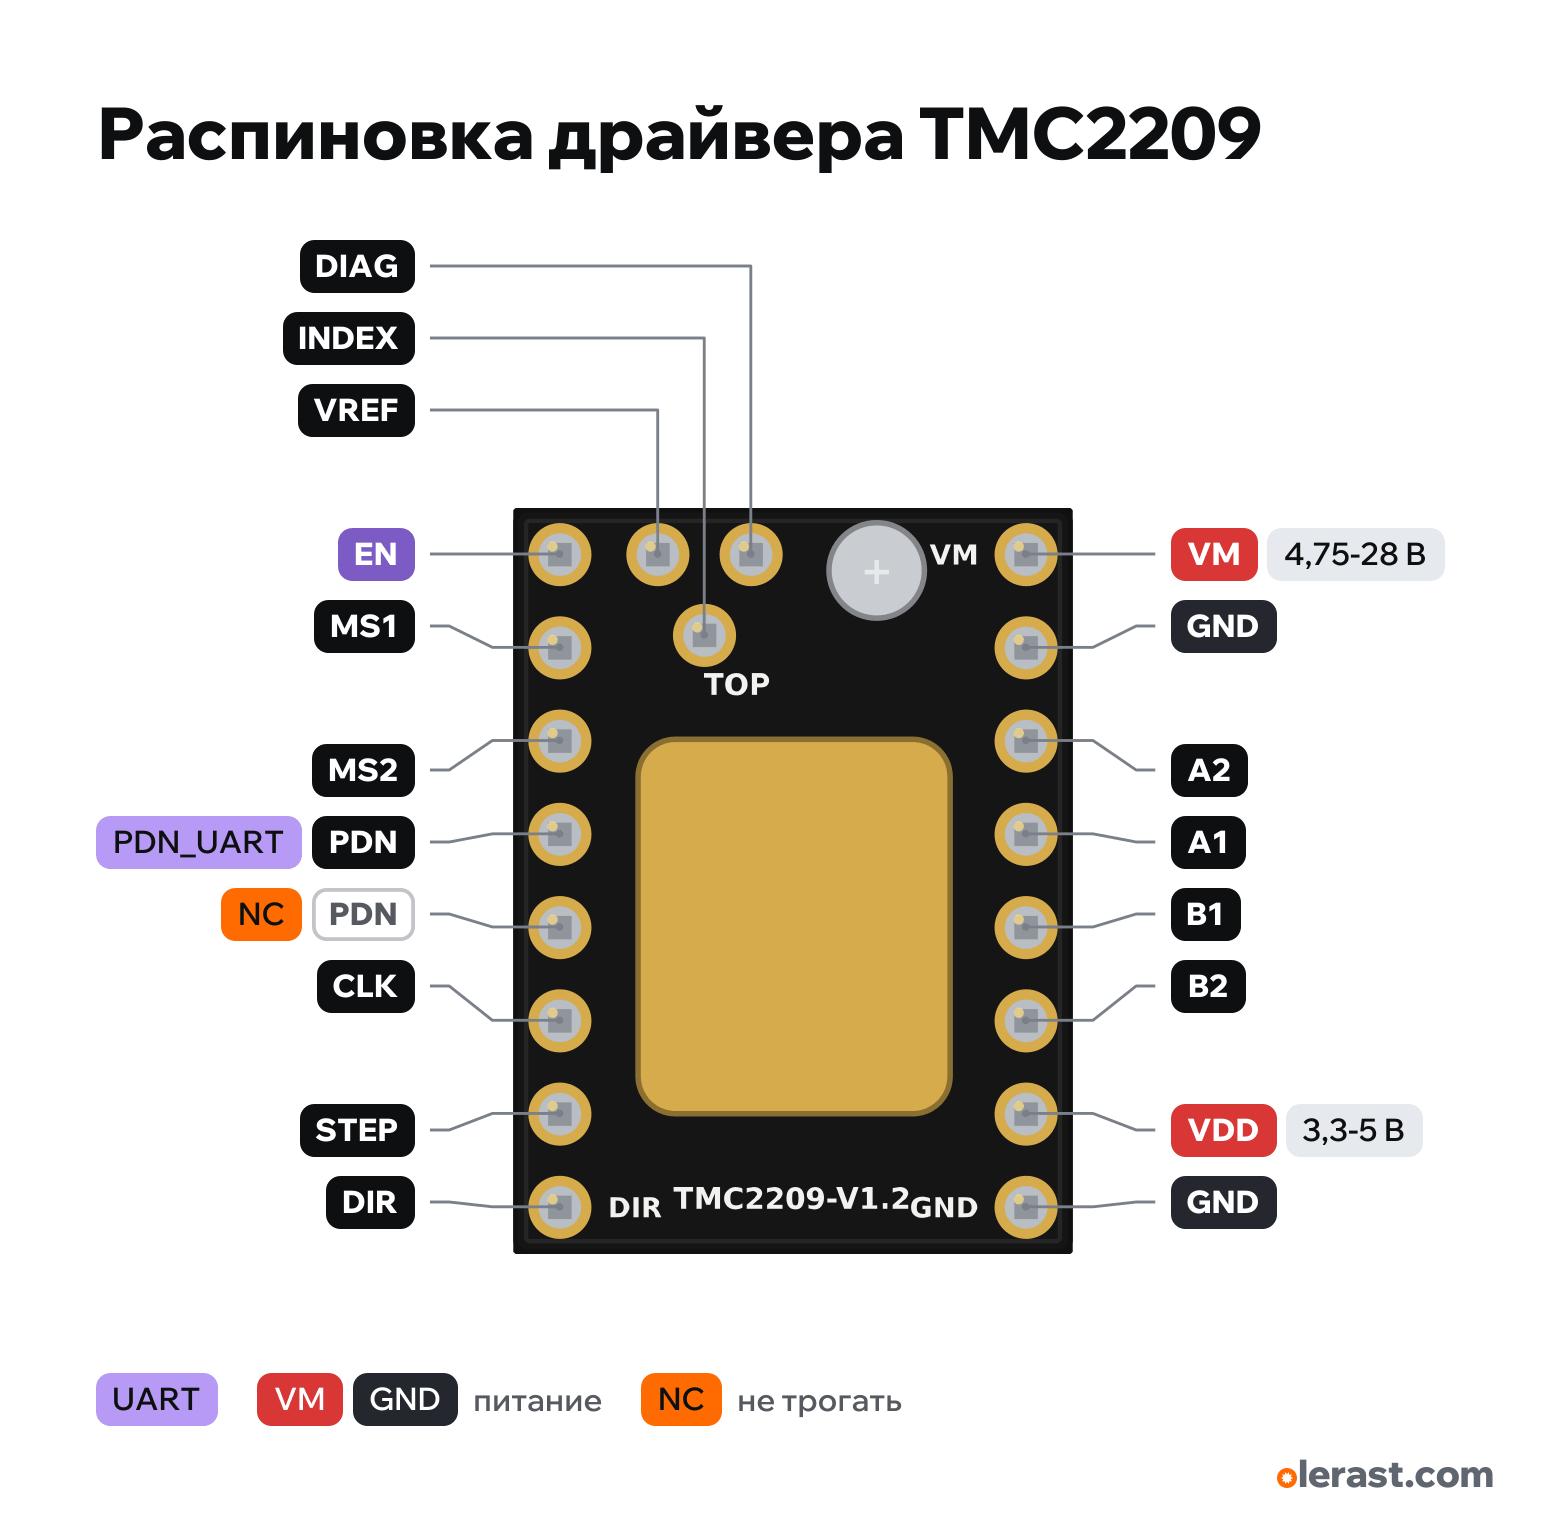
TMC2209 stepper motor driver pinout
TMC2209 stepper motor driver (StepStick, BIGTREETECH V1.2), Trinamic (ADI) TMC2209, 5 V logic, 15.24×20.32 mm, 19 pins
verified20.10.2026
View from the heatsink side (top), trimmer at top right: logic on the left (EN at the top), power and motor on the right (VM at the top), three pins VREF, INDEX, DIAG at the top center.
BuyDownload PNG- Chip
- Trinamic (ADI) TMC2209
- Logic
- 5 V
- Power
- VM 4.75-28 VVDD (VCC_IO) 3.3-5 V
Important
- Minimal connection: VM and GND from the motor supply with a 47-100 µF electrolytic capacitor, VDD and GND from 3.3-5 V logic, EN to GND, STEP and DIR to GPIOs, coils to A1-A2 and B1-B2.
- Microstepping without UART (MS2, MS1): 00 1/8, 01 1/32, 10 1/64, 11 1/16 with interpolation up to 1/256. The BIGTREETECH schematic prints the TMC2208 table (1/2 and 1/4): the TMC2209 table is different.
- Current: I_RMS = 0.325 / (Rsense + 0.02) / √2 × Vref / 2.5, Rsense 0.11 Ω. Vref is 1.2 V from the factory, about 0.9 A.
- The motor current is set by the trimmer potentiometer: the Vref voltage on its wiper. The Vref calculator on the site works out the setting for your motor (Tools, "Vref calculator").
- UART (Marlin, Klipper): PDN to the microcontroller RX directly and to TX through 1 kΩ; driver address 0-3 is set by MS1 and MS2. The firmware sets the current over UART (run_current).
- Without a heatsink about 1.2-1.7 A, with a heatsink and a fan up to 2 A RMS. Put the heatsink on the pad on top, it must not touch the pins.
- Apply VM first, then VDD (Watterott).
Revisions and clones
- BIGTREETECH TMC2209 V1.3: same connector layout according to sellers, not verified on V1.3.
- Watterott SilentStepStick TMC2209 and FYSETC TMC2209: the labels and the order of pins three to six on the left are different (SPREAD, PDN_UART, CLK), check against your own board.
- TMC2208: similar module, different microstep table (1/2, 1/4, 1/8, 1/16) and no StallGuard.
All pins
| Label | Number | Functions | Limits | Check |
|---|---|---|---|---|
| EN | EN: LOW enables the outputs, HIGH disables them (motor free) | verifiedConnect to GND or a GPIO: LOW enables the driver.Labelled on other revisions as: ENN, ENABLE | ||
| MS1 | MS1: microstep (bit 0) or UART address (bit 0), pull-down | verifiedMS2 and MS1: 00 1/8, 01 1/32, 10 1/64, 11 1/16 (1 = HIGH, MS1 is the low bit). The table differs from the TMC2208 and A4988.Labelled on other revisions as: MS1_AD0, CFG1 | ||
| MS2 | MS2: microstep (bit 1) or UART address (bit 1), pull-down | verifiedLabelled on other revisions as: MS2_AD1, CFG2 | ||
| PDN | PDN_UART: single-wire UART and automatic standstill current reduction | verifiedUART: microcontroller TX through 1 kΩ and RX directly to this pin. Leave unconnected without UART (pull-down).Labelled on other revisions as: PDN_UART, UART | ||
| PDN | not connected | verifiedSpare UART pad: not connected from the factory. Moving a resistor on the board routes UART here (BIGTREETECH).Labelled on other revisions as: PDN_UART, UART | ||
| CLK | CLK: external clock input, tie to GND to use the internal oscillator | verifiedLeave unconnected or tie to GND: the internal oscillator is used. | ||
| STEP | STEP: each edge makes one (micro)step | verified | ||
| DIR | DIR: rotation direction | verified | ||
| VM | 12 V | power input | verified47-100 µF electrolytic capacitor between VM and GND right next to the board.Labelled on other revisions as: VMOT, VS | |
| GND | Ground | verifiedMotor power ground. | ||
| A2 | A2 (OA2): coil A, second terminal | verifiedOutput to the motor winding, motor supply voltage. Don't connect to GPIO or logic.Labelled on other revisions as: 2B, M1B | ||
| A1 | A1 (OA1): coil A, first terminal | verifiedOutput to the motor winding, motor supply voltage. Don't connect to GPIO or logic.Labelled on other revisions as: 2A, M1A | ||
| B1 | B1 (OB1): coil B, first terminal | verifiedOutput to the motor winding, motor supply voltage. Don't connect to GPIO or logic.Labelled on other revisions as: 1A, M2A | ||
| B2 | B2 (OB2): coil B, second terminal | verifiedOutput to the motor winding, motor supply voltage. Don't connect to GPIO or logic.Labelled on other revisions as: 1B, M2B | ||
| VDD | 5 V | power input | verifiedLogic supply 3.3-5 V: same voltage as the microcontroller logic.Labelled on other revisions as: VCC_IO, VIO | |
| GND | Ground | verifiedLogic ground, shared with the microcontroller. | ||
| VREF | VREF: current reference voltage (trimmer wiper) | verifiedA convenient place to measure Vref with a multimeter relative to GND. | ||
| INDEX | INDEX: pulse every 4 full steps | verified | ||
| DIAG | DIAG: HIGH on a fault or when StallGuard triggers (stall sensor) | verifiedFor "sensorless" homing on a stall (Marlin, Klipper), connect this pin to the endstop input. |
Sources
Every pin is verified against the manufacturer's documents.
- BIGTREETECH TMC2209-V1.2 manualuser guide, checked 20.10.202615.24×20.32 mm; J1: 1 EN, 2 MS1, 3 MS2, 4 PDN (UART), 5 PDN (spare, not connected), 6 CLK, 7 STEP, 8 DIR; J2: 1 VM, 2 GND, 3 A2, 4 A1, 5 B1, 6 B2, 7 VDD (VCC_IO), 8 GND; VREF, INDEX, DIAG on top; VM 4.75-28 V; 2 A RMS, 2.8 A peak; MS2/MS1 table: 8, 32, 64, 16 microsteps; I_RMS = 0.325 / (Rsense + 0.02) × 1/√2 × Vref / 2.5; Vref 0.2-2.2 V, 1.2 V from the factory (0.9 A)
- BIGTREETECH TMC2209_V1.2 schematic (2019-08-05)schematic, checked 20.10.2026J3 and J4 nets as in the manual; Rsense 0R11 (0.11 Ω); PDN_UART and CLK through 20 kΩ; VCC_IO from VDD
- Watterott SilentStepStick TMC2209: pin configurationuser guide, checked 20.10.2026VM 5.5-28 V, VIO 3.3-5 V; EN: GND enabled, VIO disabled; MS1, MS2, SPREAD, PDN_UART with pull-down; DIAG high on a fault; INDEX pulse every 4 full steps; UART address set by MS1 (bit 0) and MS2 (bit 1); VM first, then VIO
Size: 0.6×0.8 in (15.24×20.32 mm), rows 12.7 mm (0.5 in) apart, 2.54 mm pitch.
FAQ
- What supply voltage does the TMC2209 stepper motor driver need?
- VM: 4.75-28 V; VDD (VCC_IO): 3.3-5 V. 5 V logic.